A robot can navigate correctly and still collect a measurement in the wrong place.
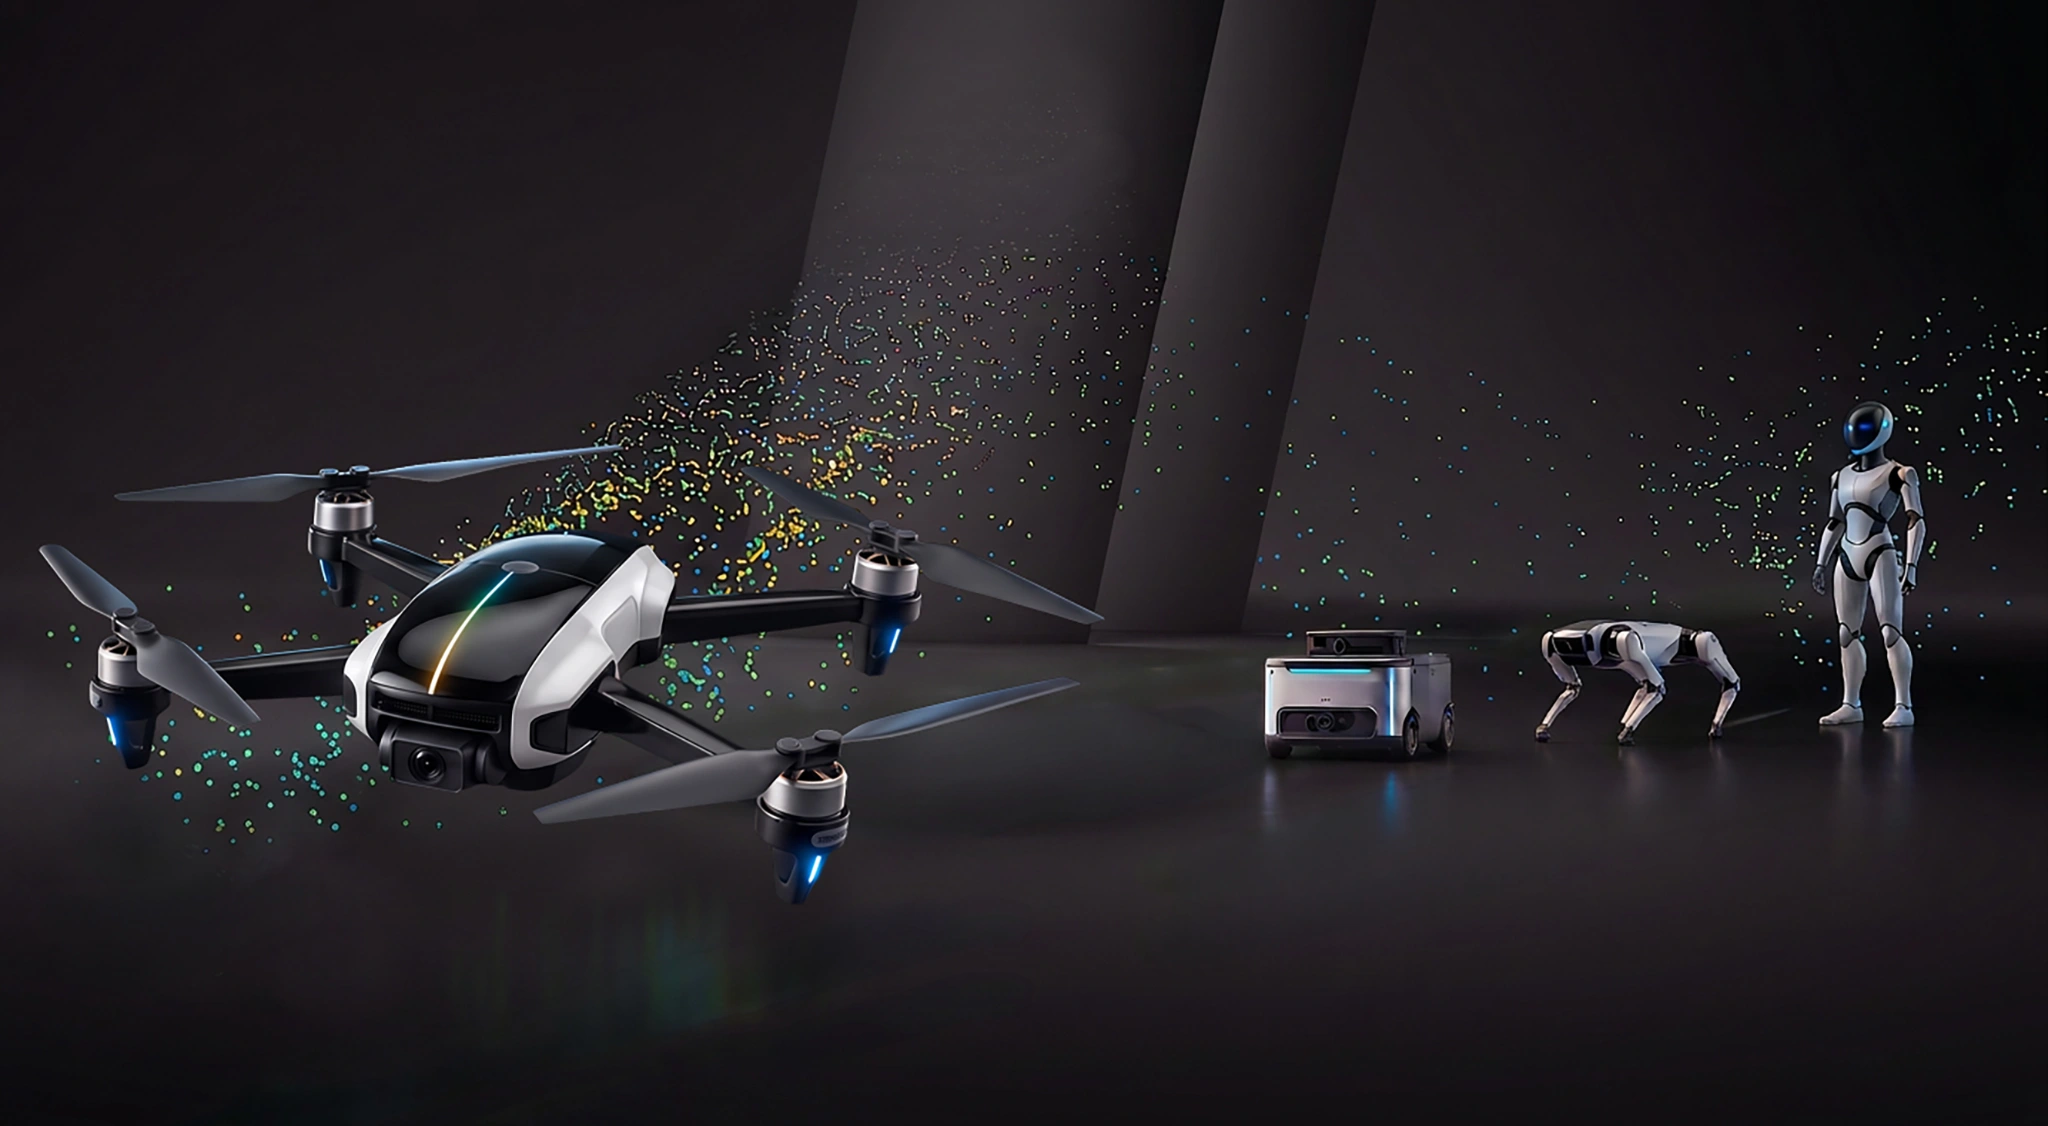
Today, NXP announced a unified robotics platform connecting sensing, real-time control, AI processing, and communications. That focus on integration connects with my research in autonomous robotic sensing for indoor environmental quality.
Consider a mobile robot carrying an environmental sensor through a building. The navigation system reports its position, while the sensor produces readings on its own schedule. If those timestamps are misaligned—or the sensor needs time to respond after the robot moves—the recorded location may not accurately represent the measurement. This is where the connections between subsystems become part of the research method. For a sensing mission, I would define how position and measurements are synchronized, how long the robot should remain at a sampling point, and how incomplete readings are identified in the dataset. I would also preserve that information with the results so another researcher can understand how they were collected. An integrated platform gives developers a starting point. A useful next step is to test one complete measurement cycle, from arrival at a location through the saved record, before expanding the mission.
#Robotics #SensorIntegration #IntelligentBuildings